GeneralizedIterativeClosestPoint6D integrates L*a*b* color space information into the Generalized Iterative Closest Point (GICP) algorithm. More...
#include <pcl/registration/gicp6d.h>

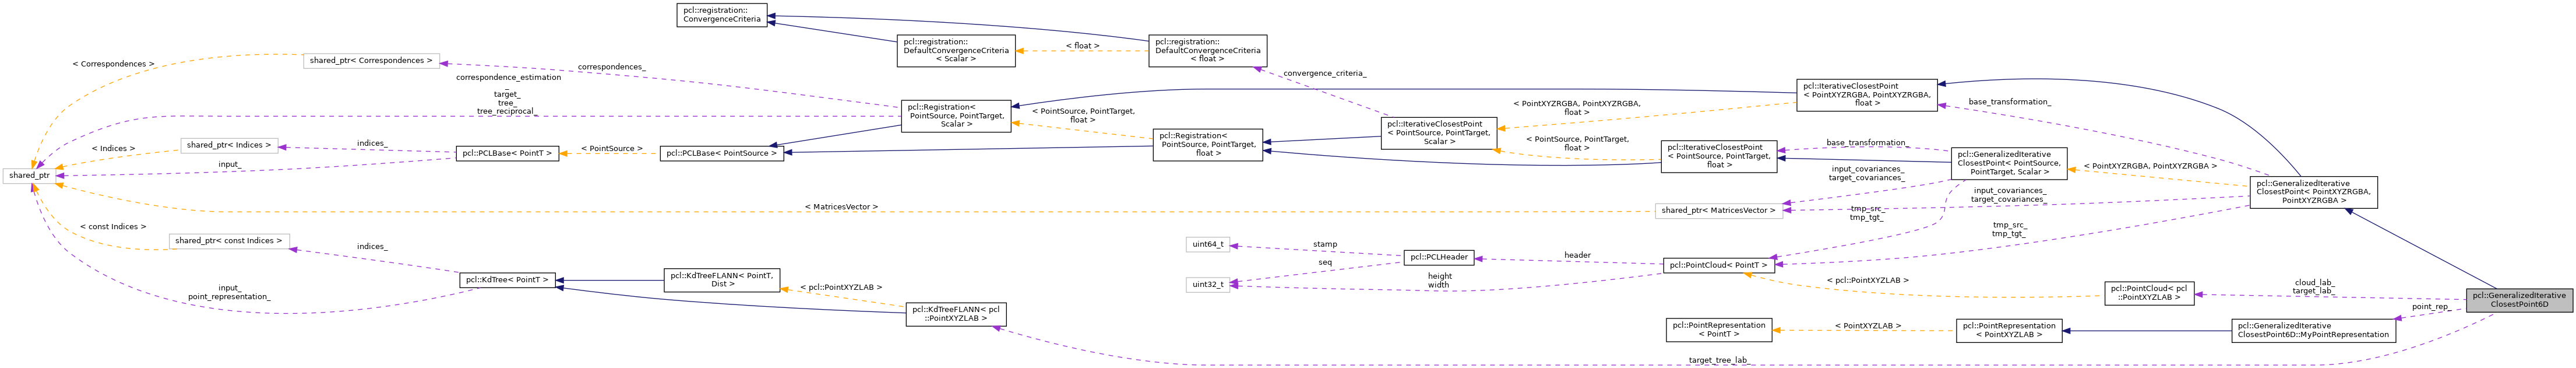
Classes |
|
| class | MyPointRepresentation |
| Custom point representation to perform kdtree searches in more than 3 (i.e. More... |
|
Public Member Functions |
|
| GeneralizedIterativeClosestPoint6D (float lab_weight=0.032f) | |
| constructor. More... |
|
| void | setInputSource (const PointCloudSourceConstPtr &cloud) override |
| Provide a pointer to the input source (e.g., the point cloud that we want to align to the target) More... |
|
| void | setInputTarget (const PointCloudTargetConstPtr &target) override |
| Provide a pointer to the input target (e.g., the point cloud that we want to align the input source to) More... |
|
 Public Member Functions inherited from pcl::GeneralizedIterativeClosestPoint< PointXYZRGBA, PointXYZRGBA > |
|
| GeneralizedIterativeClosestPoint () | |
| Empty constructor. More... |
|
| void | setInputSource (const PointCloudSourceConstPtr &cloud) override |
| Provide a pointer to the input dataset. More... |
|
| void | setSourceCovariances (const MatricesVectorPtr &covariances) |
| Provide a pointer to the covariances of the input source (if computed externally!). More... |
|
| void | setInputTarget (const PointCloudTargetConstPtr &target) override |
| Provide a pointer to the input target (e.g., the point cloud that we want to align the input source to) More... |
|
| void | setTargetCovariances (const MatricesVectorPtr &covariances) |
| Provide a pointer to the covariances of the input target (if computed externally!). More... |
|
| void | estimateRigidTransformationBFGS (const PointCloudSource &cloud_src, const pcl::Indices &indices_src, const PointCloudTarget &cloud_tgt, const pcl::Indices &indices_tgt, Matrix4 &transformation_matrix) |
| Estimate a rigid rotation transformation between a source and a target point cloud using an iterative non-linear BFGS approach. More... |
|
| const Eigen::Matrix3d & | mahalanobis (std::size_t index) const |
| void | computeRDerivative (const Vector6d &x, const Eigen::Matrix3d &dCost_dR_T, Vector6d &g) const |
| Computes the derivative of the cost function w.r.t rotation angles. More... |
|
| void | setRotationEpsilon (double epsilon) |
| Set the rotation epsilon (maximum allowable difference between two consecutive rotations) in order for an optimization to be considered as having converged to the final solution. More... |
|
| double | getRotationEpsilon () const |
| Get the rotation epsilon (maximum allowable difference between two consecutive rotations) as set by the user. More... |
|
| void | setCorrespondenceRandomness (int k) |
| Set the number of neighbors used when selecting a point neighbourhood to compute covariances. More... |
|
| int | getCorrespondenceRandomness () const |
| Get the number of neighbors used when computing covariances as set by the user. More... |
|
| void | setMaximumOptimizerIterations (int max) |
| Set maximum number of iterations at the optimization step. More... |
|
| int | getMaximumOptimizerIterations () const |
| Return maximum number of iterations at the optimization step. More... |
|
| void | setTranslationGradientTolerance (double tolerance) |
| Set the minimal translation gradient threshold for early optimization stop. More... |
|
| double | getTranslationGradientTolerance () const |
| Return the minimal translation gradient threshold for early optimization stop. More... |
|
| void | setRotationGradientTolerance (double tolerance) |
| Set the minimal rotation gradient threshold for early optimization stop. More... |
|
| double | getRotationGradientTolerance () const |
| Return the minimal rotation gradient threshold for early optimization stop. More... |
|
| Public Member Functions inherited from pcl::IterativeClosestPoint< PointXYZRGBA, PointXYZRGBA, float > |
|
| IterativeClosestPoint () | |
| Empty constructor. More... |
|
| IterativeClosestPoint (const IterativeClosestPoint &)=delete | |
Due to convergence_criteria_ holding references to the class members, it is tricky to correctly implement its copy and move operations correctly. More... |
|
| IterativeClosestPoint (IterativeClosestPoint &&)=delete | |
| IterativeClosestPoint & | operator= (const IterativeClosestPoint &)=delete |
| IterativeClosestPoint & | operator= (IterativeClosestPoint &&)=delete |
| ~IterativeClosestPoint () override=default | |
| Empty destructor. More... |
|
| pcl::registration::DefaultConvergenceCriteria< float >::Ptr | getConvergeCriteria () |
| Returns a pointer to the DefaultConvergenceCriteria used by the IterativeClosestPoint class. More... |
|
| void | setInputSource (const PointCloudSourceConstPtr &cloud) override |
| Provide a pointer to the input source (e.g., the point cloud that we want to align to the target) More... |
|
| void | setInputTarget (const PointCloudTargetConstPtr &cloud) override |
| Provide a pointer to the input target (e.g., the point cloud that we want to align the input source to) More... |
|
| void | setUseReciprocalCorrespondences (bool use_reciprocal_correspondence) |
| Set whether to use reciprocal correspondence or not. More... |
|
| bool | getUseReciprocalCorrespondences () const |
| Obtain whether reciprocal correspondence are used or not. More... |
|
| Public Member Functions inherited from pcl::Registration< PointSource, PointTarget, Scalar > |
|
| Registration () | |
| Empty constructor. More... |
|
| ~Registration () override=default | |
| destructor. More... |
|
| void | setTransformationEstimation (const TransformationEstimationPtr &te) |
| Provide a pointer to the transformation estimation object. More... |
|
| void | setCorrespondenceEstimation (const CorrespondenceEstimationPtr &ce) |
| Provide a pointer to the correspondence estimation object. More... |
|
| virtual void | setInputSource (const PointCloudSourceConstPtr &cloud) |
| Provide a pointer to the input source (e.g., the point cloud that we want to align to the target) More... |
|
| PointCloudSourceConstPtr const | getInputSource () |
| Get a pointer to the input point cloud dataset target. More... |
|
| virtual void | setInputTarget (const PointCloudTargetConstPtr &cloud) |
| Provide a pointer to the input target (e.g., the point cloud that we want to align the input source to) More... |
|
| PointCloudTargetConstPtr const | getInputTarget () |
| Get a pointer to the input point cloud dataset target. More... |
|
| void | setSearchMethodTarget (const KdTreePtr &tree, bool force_no_recompute=false) |
| Provide a pointer to the search object used to find correspondences in the target cloud. More... |
|
| KdTreePtr | getSearchMethodTarget () const |
| Get a pointer to the search method used to find correspondences in the target cloud. More... |
|
| void | setSearchMethodSource (const KdTreeReciprocalPtr &tree, bool force_no_recompute=false) |
| Provide a pointer to the search object used to find correspondences in the source cloud (usually used by reciprocal correspondence finding). More... |
|
| KdTreeReciprocalPtr | getSearchMethodSource () const |
| Get a pointer to the search method used to find correspondences in the source cloud. | |